 HERMESS
Power system stabilizers#
The stabilizer strategy is plugged onto a machine with the pss keyword,
for example pss = "PSSKundur". It reads the speed deviation and produces
the stabilizing signal \(V_s\), which the AVR sums into its voltage error.
|
Class |
Description |
|---|---|---|
|
Single-input (speed) power system stabilizer: gain, washout, and two lead-lag stages (Kundur, Power System Stability and Control, 1994). |
|
|
Speed-input PSS of the 14-generator South East Australian benchmark (Gibbard and Vowles 2014, Fig. 23 and eqs. (7)-(10)). |
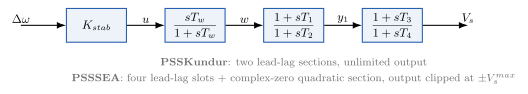
Speed-input stabilizer: gain, washout and lead-lag stages.#
- class hermess.devices.pss.PSSKundur[source]
Single-input (speed) power system stabilizer: gain, washout, and two lead-lag stages (Kundur, Power System Stability and Control, 1994).
Selected on a machine line with
pss = "PSSKundur".Model. Transfer function \(V_s = K_{stab} \frac{s T_w}{1 + s T_w} \frac{1 + s T_1}{1 + s T_2} \frac{1 + s T_3}{1 + s T_4} \, \Delta\omega\) with \(\Delta\omega = \omega - \omega_{net}\), realized as three lag-pole states plus feedthrough:
\[\begin{split}u &= K_{stab} \, \Delta\omega \\ T_w \, \dot{v}_w &= u - v_w, \qquad w = u - v_w \\ T_2 \, \dot{v}_{l1} &= w - v_{l1}, \qquad y_1 = \Bigl(1 - \frac{T_1}{T_2}\Bigr) v_{l1} + \frac{T_1}{T_2} w \\ T_4 \, \dot{v}_{l2} &= y_1 - v_{l2}, \qquad 0 = -V_s + \Bigl(1 - \frac{T_3}{T_4}\Bigr) v_{l2} + \frac{T_3}{T_4} y_1\end{split}\]The washout blocks DC, so at equilibrium \(v_w = v_{l1} = v_{l2} = V_s = 0\) and the PSS does not shift the operating point. The output \(V_s\) has direct feedthrough on \(\Delta\omega\) and is therefore a device-private algebraic variable, summed into the AVR voltage error via
Synchronous.pss_signal. This model has no output limit (comparePSSSEA).Symbols.
Code
Symbol
Meaning
Default
K_stab\(K_{stab}\)
stabilizer gain
10
Tw\(T_w\)
washout time constant [s]
10
T1\(T_1\)
lead-lag 1 lead time constant [s]
0.05
T2\(T_2\)
lead-lag 1 lag time constant [s]
0.02
T3\(T_3\)
lead-lag 2 lead time constant [s]
0.05
T4\(T_4\)
lead-lag 2 lag time constant [s]
0.02
vw\(v_w\)
washout low-pass state [p.u.]
vl1\(v_{l1}\)
lead-lag 1 lag state [p.u.]
vl2\(v_{l2}\)
lead-lag 2 lag state [p.u.]
Vs\(V_s\)
stabilizing signal to the AVR (private algebraic) [p.u.]
- class hermess.devices.pss.PSSSEA[source]
Speed-input PSS of the 14-generator South East Australian benchmark (Gibbard and Vowles 2014, Fig. 23 and eqs. (7)-(10)).
Selected on a machine line with
pss = "PSSSEA".Model. Transfer function
\[V_s = \mathrm{sgn} \cdot K_{stab} \cdot \frac{s T_w}{1 + s T_w} \cdot \prod_{i=1}^{4} \frac{1 + s T_{z,i}}{1 + s T_{p,i}} \cdot \frac{1 + a_q s + b_q s^2}{(1 + s T_{p5})(1 + s T_{p6})} \cdot (\omega - \omega_{net})\]with overall gain \(K_{stab} = D_e K_c\) (\(D_e\) = 20 p.u. damping gain on machine MVA base, \(K_c\) from Tables 17-20). The four first-order sections cover the real zero/pole chains of eqs. (7)-(9); the quadratic section carries the complex-zero pair of eqs. (8) and (10). Unused first-order slots are exactly unity with \(T_{z,i} = T_{p,i}\); an unused quadratic section is exactly unity with \(a_q = T_{p5} + T_{p6}\), \(b_q = T_{p5} T_{p6}\). \(\mathrm{sgn} = -1\) for a hydro machine operating in pumping mode.
Realization: washout and first-order sections as lag state plus feedthrough (as in
PSSKundur; \(T_{p,i} > 0\) required); the quadratic section in controllable canonical form with feedthrough \(c = b_q/(T_{p5} T_{p6})\):\[\begin{split}\dot{v}_{q1} &= v_{q2}, \qquad T_{p5} T_{p6} \, \dot{v}_{q2} = -v_{q1} - (T_{p5} + T_{p6}) v_{q2} + u \\ y &= c \, u + (1 - c) \, v_{q1} + \bigl(a_q - c \,(T_{p5} + T_{p6})\bigr) v_{q2}\end{split}\]The output is hard-clipped at the published limit \(\pm V_s^{max}\) (always active, not gated by
incl_lim); the operating point sits at \(V_s = 0\) with unit slope, so the small-signal behavior is unchanged.Symbols.
Code
Symbol
Meaning
Default
K_stab\(K_{stab}\)
overall gain (\(D_e K_c\), machine base)
10
Tw\(T_w\)
washout time constant [s]
7.5
Tz1/Tp1\(T_{z,1}, T_{p,1}\)
section 1 lead / lag time constants [s]
1e-3
Tz2/Tp2\(T_{z,2}, T_{p,2}\)
section 2 lead / lag time constants [s]
1e-3
Tz3/Tp3\(T_{z,3}, T_{p,3}\)
section 3 lead / lag time constants [s]
1e-3
Tz4/Tp4\(T_{z,4}, T_{p,4}\)
section 4 lead / lag time constants [s]
1e-3
a_q\(a_q\)
quadratic numerator s-coefficient
2e-4
b_q\(b_q\)
quadratic numerator s^2-coefficient
1e-8
Tp5/Tp6\(T_{p5}, T_{p6}\)
quadratic denominator time constants [s]
1e-4
sgn\(\mathrm{sgn}\)
output sign (-1 when pumping)
1
Vs_max\(V_s^{max}\)
output limit (hard clip, always active)
0.1
vw\(v_w\)
washout low-pass state [p.u.]
v1/v2/v3/v4\(v_1 \dots v_4\)
first-order section lag states [p.u.]
vq1/vq2\(v_{q1}, v_{q2}\)
quadratic section states [p.u.]
Vs\(V_s\)
stabilizing signal to the AVR (private algebraic) [p.u.]